 sarcastic_guy
Introduction
Picture an early morning drive on Ngong Road, the city easing into movement. An electric drive system turns stored energy into clean motion. The electric car drive system now sits at the center of that shift, as drivers seek quieter rides, lower costs, and real range. Global EV sales rose by over a third last year, and local fleets are testing routes with precision data. Yet one big question hangs over every purchase: how do we choose a system that performs well in traffic, on hills, and in heat, not just in lab tests?

We will take a direct view and compare what makes a drive unit efficient, durable, and easy to control. We will weigh motor control, inverter choices, and cooling approaches (pole-pole, hakuna shida). Then we ask: which design gives you fewer surprises on the road, and more uptime in the yard? Let us step into the details.
Where Traditional Approaches Fall Short
What are we missing?
Earlier, many teams chased peak power numbers. That looks good in a brochure. But daily driving is about partial load and start-stop events. Traditional inverter stacks based on older IGBTs can run hot at mid-load. That means derating kicks in and torque drops. Add torque ripple from basic control loops, and you feel a shudder at low speed—funny how that works, right? Field-oriented control (FOC) helps, but if the tuning ignores thermal limits on the DC bus and weak stator cooling, the gain is short-lived. And when the battery state of charge dips, the same flaws get louder.
Look, it’s simpler than you think. The pain point hides in integration. A motor with strong magnets and a neat gearbox still fails if the power electronics waste energy in switching losses. Poor thermal management pushes the inverter to protect itself, so acceleration feels late. CAN bus logs then flood with warnings instead of insight. Users blame “range,” but the root cause is control inefficiency and heat. Traditional fixes, like bigger radiators or conservative torque limits, treat symptoms. The system needs smarter switching strategies, lower-loss devices, and tighter coupling between thermal sensors and control maps.
New Principles, Real Gains
What’s Next
The next wave is clear and practical. Silicon carbide (SiC) MOSFET inverters cut switching losses and run cooler than classic IGBTs. That lifts efficiency in the real world, not just at peak. Pair SiC with model predictive control, and you smooth torque while protecting components in fast transients. Edge computing nodes can sit near the motor to process sensor data with low latency—temperature, rotor angle, and phase current—so the controller reacts in milliseconds. The result: less torque ripple, fewer thermal spikes, and quieter NVH. An integrated e-axle also shortens cabling, trims EMI, and reduces mass. Small changes add up—over a drive cycle, they feel big.
Cooling is also shifting. Oil spray or direct stator cooling moves heat away faster than simple jackets. That keeps the inverter and motor close to optimal temperature even in Nairobi heat. Regenerative braking maps now adapt to tyre grip and battery temperature, protecting the pack while saving energy. When you compare systems side by side, the winner is not only the motor. It is the electric car drive system that blends SiC power converters, smart control, and active thermal design. You get wider efficiency islands across the speed-torque map—so city routes, hills, and bypass runs all benefit. And maintenance gets simpler, because the logs point to causes, not noise—powerful, yet calm.
How to Choose: Metrics That Matter
To wrap up, here is a practical way to compare options and cut through the hype. Use three clear metrics that you can measure on your routes. First, dynamic efficiency coverage: test efficiency across a real drive cycle (cold start, stop-go, hill, cruise) and track watt-hours per kilometer at 20–60% load. The broader the high-efficiency zone, the better your cost per km. Second, thermal headroom: measure how long the system holds continuous torque before derating at 35°C ambient. More headroom means fewer slowdowns under heat. Third, control fidelity: log torque tracking error and inverter switching losses during fast transients; lower error and lower loss show a well-tuned loop and a clean DC bus. If two systems tie on peak power, these three will break the tie—every time.
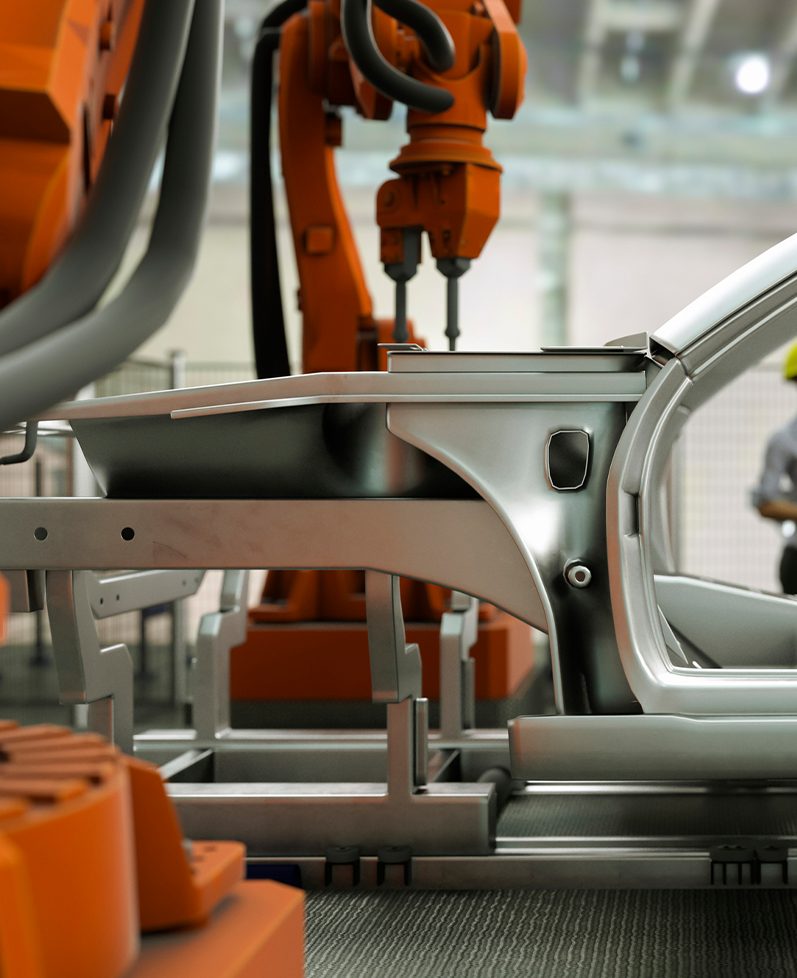
These insights echo what we saw above: losses hide at mid-load, cooling makes or breaks consistency, and smart control beats brute force. Choose what matches your routes, climate, and maintenance plan. Then validate with data, not promises—sawa? For ongoing technical resources and industry practice, you may learn more from LEAD.

 ahead_time
 Ethan Riley
 quadro_bike